01 / STATICARCHIVED
The frozen safety case
A revision changes. The binder cannot show which claim lost its support.
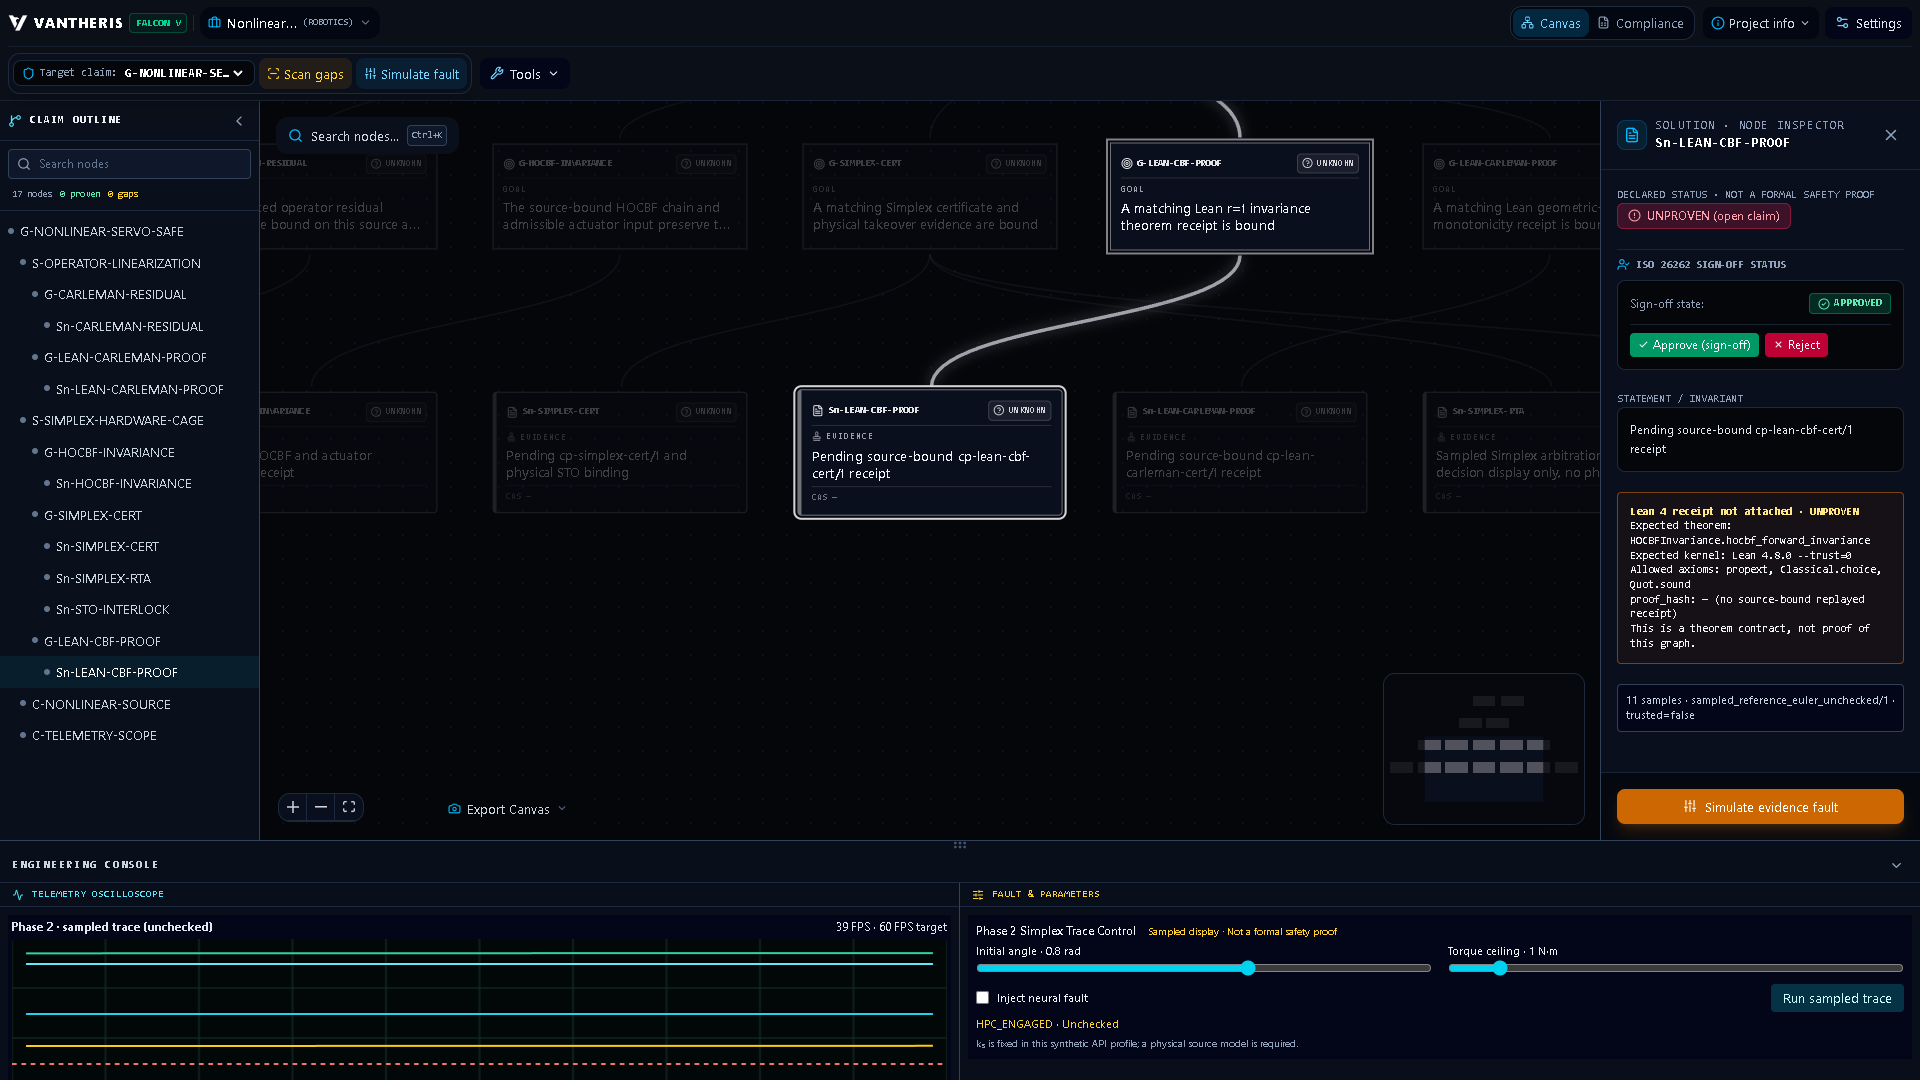
Versioned claims, exact model checks and explicit limits—visible in one engineering workspace.
A claim is useful when its dependencies and changes remain inspectable.
A revision changes. The binder cannot show which claim lost its support.
Trace evidence versions, affected claims and the scope of each check.
Change an exact-integer demonstration model and view its sampled trace. No SMT or physical safety decision runs in this browser.
Carleman and Koopman profiles carry explicit working domains and residual bounds.
Exact Lie chains and interval checks for stated polynomial models.
Sampled software decisions and STO requests. Hardware isolation and WCET remain unverified.
Versioned source links, SQLite records and scoped Lean receipts keep the argument inspectable.
Model profiles are research and engineering tools; domain certification needs separate evidence.
Outline, claim canvas, sampled telemetry and receipt inspector—docked into one local workspace.
Verify the file hash before installation. This build is unsigned; VirusTotal has not been verified for this binary. Local deployment policy remains your responsibility.
Download Windows installer ↓Open .sha256 checksum file ↗14770cb8b35056666cce019ff6928db4b4ea4c9ce1356e39a9fc71b118d44992Get-FileHash "Falcon-V-Studio_0.2.1_x64-setup.exe" -Algorithm SHA256File integrity is not a digital signature or a malware clearance.
Engineering assurance earns trust by exposing its assumptions, not hiding its uncertainty.
We target the exact nightmare scenarios keeping principal engineers awake across high-risk physical AI domains.
Lane departure risks under wet/ice conditions (μ=0.38) and 14ms CAN bus latency.
1.1 µs KKT projection lock.
Physical boundaries enforced regardless of road friction.
Jackknife risks during delayed braking of a 40-ton truck at 110 km/h.
Deterministic intersample braking buffer (δ).
Mathematically impossible to jackknife.
Autopilot disorientation and friendly-fire risks under EW jamming and GPS spoofing.
Hardware register-level kinetic corridor lock.
Munition physically bounded to authorized airspace.
Lethal torque bursts to humans caused by VLA token hallucinations in a 70kg robot.
O(1) actuator kinetic energy ceiling.
Guaranteed safe human-robot physical collaboration.
300-ton haul truck slipping into ravines when dust and mud blind the LiDAR.
Traction-aware slope tipping barrier.
Continuous grip bounds despite sensor total-loss.
AGV crashing into pedestrians during 50ms packet loss in tele-operation.
Automatic MRM hardware heartbeat sentinel.
Instant Safe Torque Off upon packet drop.
Unnecessary stops or derailments spanning kilometers of braking distance.
Z3 SMT velocity ceiling synthesis.
Maximal throughput with mathematically verified braking limits.
Millimetric neural controller deviation tearing a critical artery.
Sub-micron impenetrable keep-out zones.
Surgical boundaries physically locked.
From zero-install audits to bare-metal RTOS production fleets.